
Embodied Robot Power Bus Wire Harness
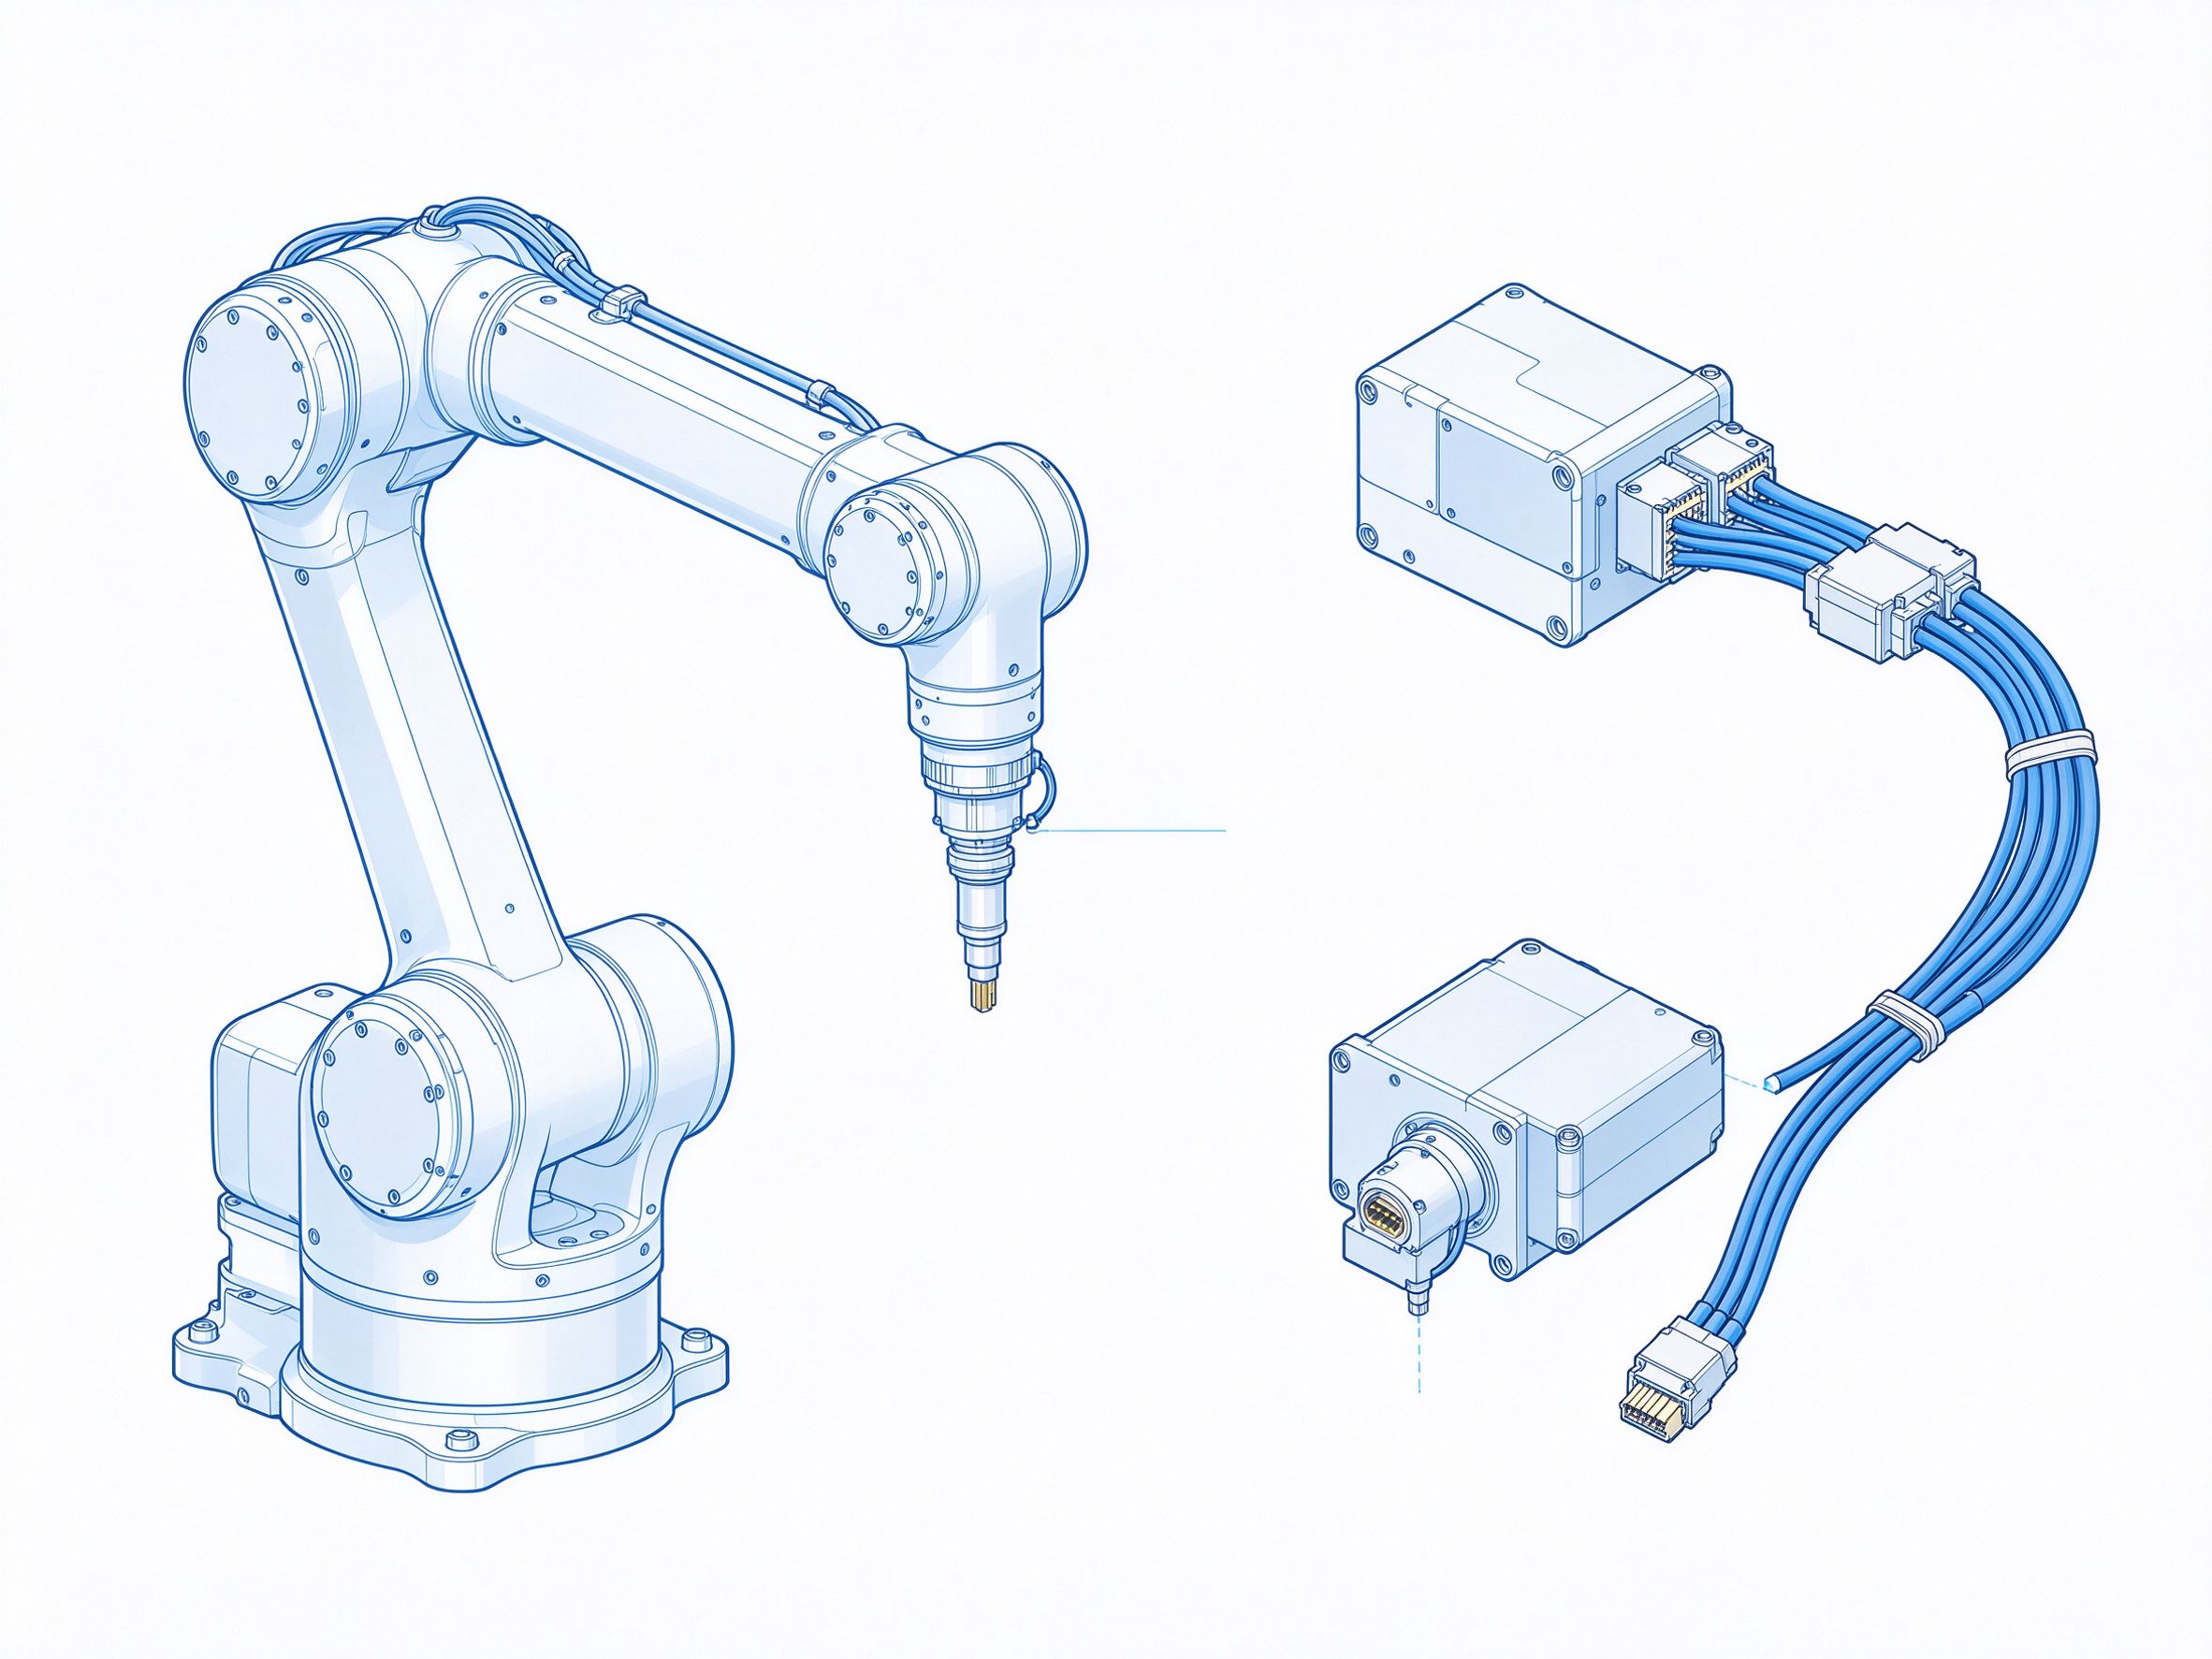
Product Introduction
This embodied robot power bus harness forms the main power trunk inside humanoid robots, feeding the joint motor controllers, main control board and distributed sensors from the battery. Designed around the robot's internal mechanical layout, it combines a small bend radius with reliable contacts so power reaches every actuator while keeping overall mass low.
Product Features
- Power trunk design that branches out to each limb and torso module
- Lightweight flexible conductors to reduce load on moving joints
- Independent power and signal branches for clean distribution
- Shielded low-voltage lines guarding control and sensor signals
- Pluggable keyed connectors for fast assembly and maintenance
Technical Specifications
- Applications: embodied and humanoid robot power systems
- Conductors: flexible copper wires, gauge selected by actuator current
- Terminals: robot-grade crimped terminals with secure contact
- Jacket selected for internal robot operating conditions
- Customization: length, branches and color coding configurable per drawing
Quality Assurance
We manufacture to customer drawings and samples and support small-batch prototyping through mass production. Every harness undergoes 100% continuity testing and high-potential testing before shipment. Contact us for a detailed quote.