
Embodied Robot Power Bus Wire Harness
Product Introduction
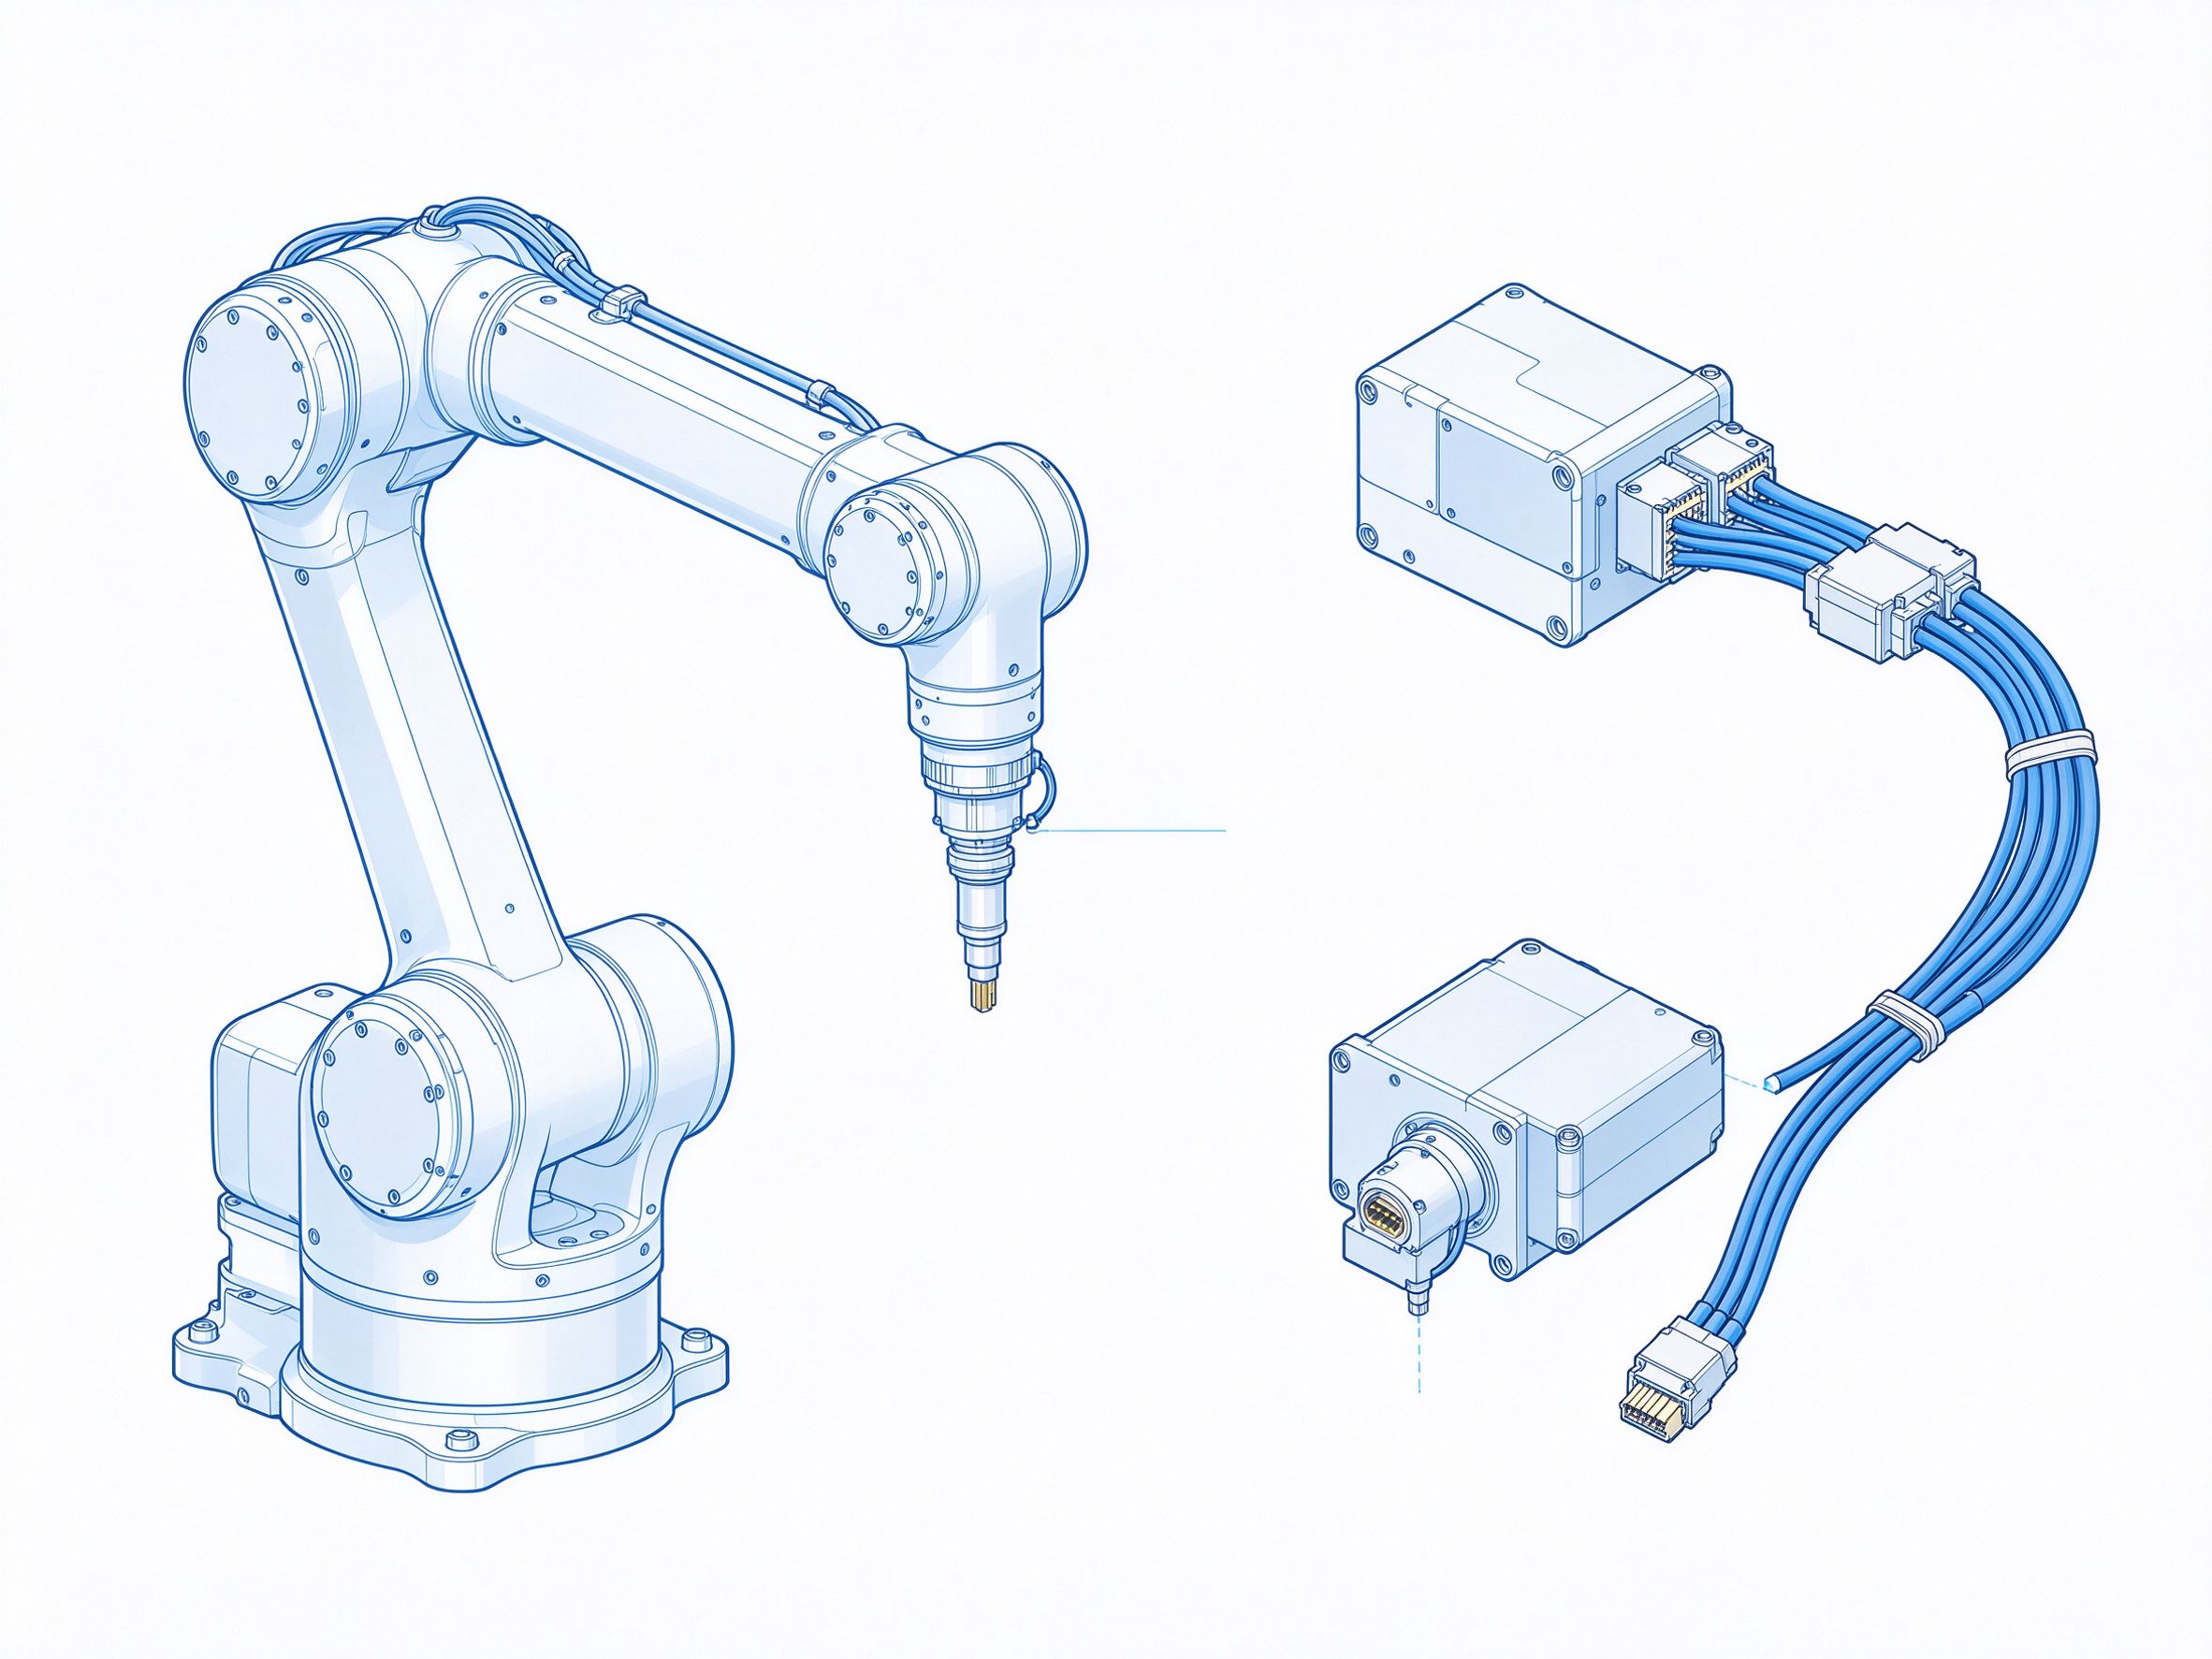
Embodied robot power bus harnesses act as the central power distribution backbone inside humanoid and embodied robots. They carry battery power out to the joint motor drivers, main control board, sensor units and actuators through a compact bus architecture. To suit the constrained space and dynamic movement of a humanoid body, the harness uses flexible lightweight conductors, organized branches and reliable pluggable connections.
Product Features
- Centralized power bus layout that reduces redundant wiring across the body
- Flexible conductors with thin jackets to save weight in moving limbs
- Separated power branches for joint actuators and low-voltage sensor circuits
- Shielded signal pairs that protect sensitive control lines from drive noise
- Keyed connectors that simplify module assembly and field servicing
Technical Specifications
- Applications: humanoid and embodied robot power distribution systems
- Conductors: flexible copper conductors, gauge selected by branch current
- Connectors: compact robot-grade pluggable connectors
- Insulation selected for the robot's internal operating temperature
- Customization: branch positions, length and wiring order configurable per robot design
Quality Assurance
We manufacture to customer drawings and samples and support small-batch prototyping through mass production. Every harness undergoes 100% continuity testing and high-potential testing before shipment. Contact us for a detailed quote.