
Humanoid Robot Servo Joint Wire Harness
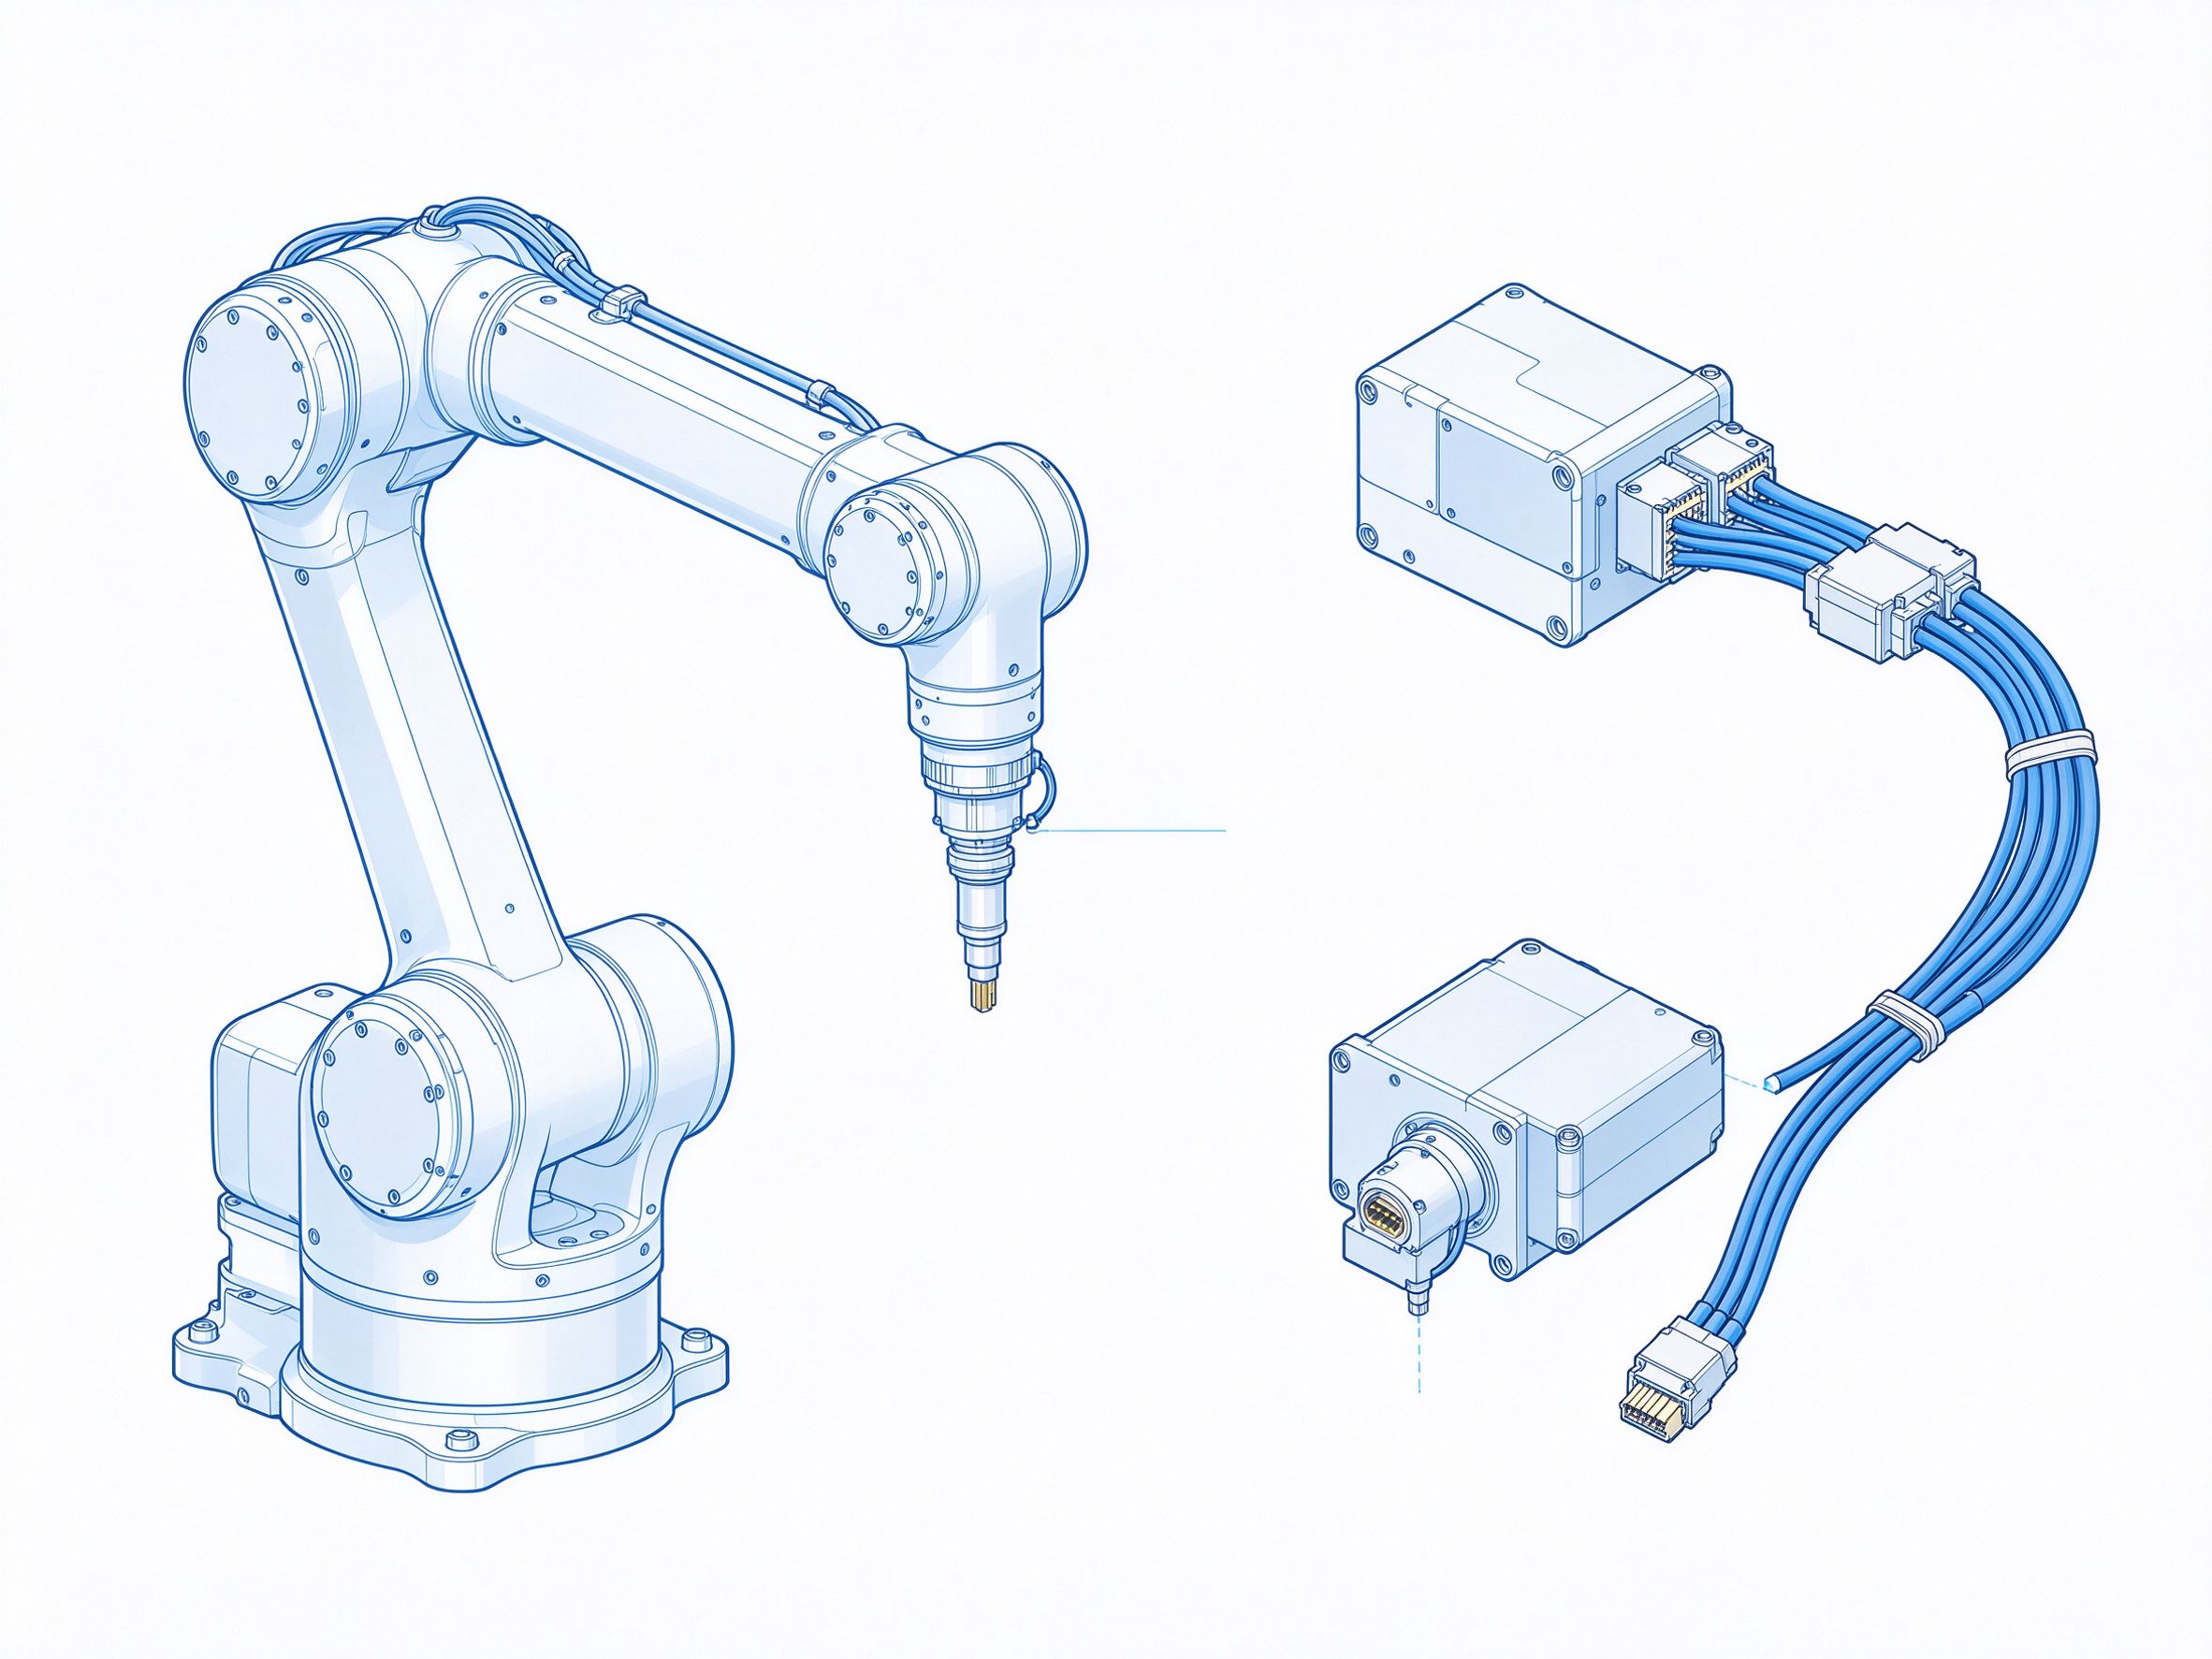
Product Introduction
This harness is built for the servo joints of humanoid and embodied robots, routing motor power, encoder feedback and brake signals through a continuously rotating joint. It combines high flexibility, torsion resistance and a lightweight form factor so the joint can move freely without compromising signal integrity.
Product Features
- Highly flexible cable designed for repeated bending and torsion at the joint
- Shielded encoder lines that preserve position feedback accuracy
- Lightweight construction that reduces joint inertia and payload burden
- Integrated power, signal and brake circuits in one compact routing
- Durable jacket resistant to abrasion in repeated joint motion
Technical Specifications
- Applications: humanoid robot servo joints, collaborative robot joints
- Conductors: high-flex stranded copper wire with a flexible jacket
- Connectors: compact motor-side connectors matched to the joint module
- Customization: length, branch structure and wire sequence per joint drawing
Quality Assurance
We manufacture to customer drawings and samples, supporting small-batch prototyping and volume production. Every harness undergoes 100% continuity testing and high-potential testing before shipment. Contact us for a detailed quote.